
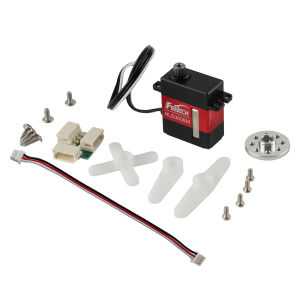
Feetech HLS3606M Constant Force Control 360° 6kg Torque Servo 6V Programming Stem Educational Building Robot Arm/Learning Robot
Products Description6Kg.cm Torque Control Upgrade Micro Magnetic Encoder Single Shaft Servo HLS3606M 360 Angle Serial Bus Servo The HLS3606M servomotor is high quality from the Feetech brand and can be used in 360° position control mode or in continuous mode, its housing is made of aluminum alloy and it has copper gears as well as ball bearings, all this ensures good rigidity of the engine block as well as good thermoregulation. This servomotor has a maximum torque of 6kg.cm. It is said to be intelligent because it can send information back to the user about its position, charge, supply voltage, current consumed and temperature. The HLS3606M servomotor uses the RS485 3P communication protocol so it can very easily be controlled by Arduino with the help of the TTL/RS485 FE-URT-1 converter from Feetech. Being also equipped with external connectors, it can very easily be connected in cascade. This therefore makes it ideal for creating mechanical arms or other advanced robots.HLS3606MSize:23X12X27.5mm Weight: 20.6g Gear: steel gear Gear ratio: 1/205 Horn type: 25T/OD4.95mm Motor: coreless motor Angle Sensor: 12Bits Magnetic Coding Connector and cable: 15cm 3pins cable with 5264-3p connectorOperating voltage: 4.8V-6VTerminal resistance: 2.8Ω Kt constant: 4.5kg.cm/A Operating Temperature Range: -20℃~60℃ Specification for 4.8V:No load speed: 0.11s/60° (90RPM) No load current:130mA Stall torque: 4.8kg.cm (66.77oz.in) Stall current: 1.1A Specification for 6.0V:No load speed: 0.09s/60° (111RPM) No load current:150mA Stall torque: 6kg.cm (83.47oz.in) Stall current: 1.3AControl Specification:Control Algorithm: PID Communication Baud Rate: 38400bps ~ 1 Mbps Neutral Position: 180°(2048) Running degree: 360°(when 0~4096) Rotating Direction: Clockwise(0→4096) Electronic resolution: 0.088°(360°/4096)Function:Feedback: Load/ Position/ Speed / Input Voltage/ Temperature/ Current Electronic Protection: Over load/ voltage/ hot protection Operating Modes: model 0:servo model model 1: Motor constant speed mode model 2: Motor constant current mode Multi-Loop Mode: Maximum accuracy can be plus or minus 7 turns absolute position Control, but the number of power-off coil is not saved. Torque Control: The output torque value is set, and the servo can maintain this torque. Double Shaft:

GlobalTechMart
Review
You May Also Like
Dinosaur Park Building includes: 4 cars 2 dinosaur 1 building batteries NOT INCLUDED
All U Want - 100pcs Matte Card Sleeves Film Protector Card Cover
Lego Fortnite 77080 Supply Drop (2026)
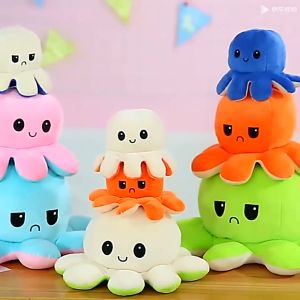
Double-sided Flip Plush Octopus Toy Reversible Flip Octopus Doll Simulation Soft Plush Toys
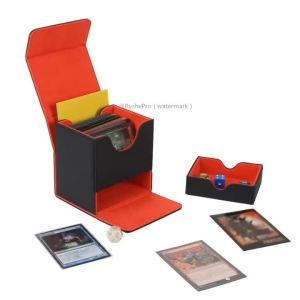
Commander Card Deck Box for MTG Holds 100+ Deck Box with 2 Dividers and Dice Tray Fits for MTG PTCG Magic Baseball Sports Cards
Game Genshin Impact Cosplay The Past SCARAMOUCHE Cosplay Costume KUNIKUZUSHI Kimono Cosplay Full Set♢X1120
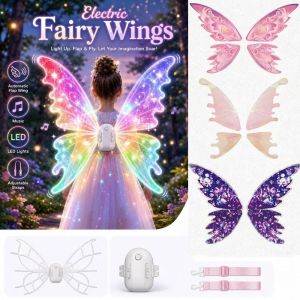
RGFV MALL Light Up Electric Fairy Wings with LED Lights with Music Moving Butterfly Wings Cosplay Dress Up Gift Fairy Glowing Wings Children Toys
BILIBILI | 500 1000 1200 2000pcs Jigsaw Puzzle Scenery Landscape Painting For Adults Home Decor Family Game Gift
Hello Kitty Party Theme Complete Garland Balloon Set Happy Birthday Banner Decor Foil Rubber Pink
Lego Icons 11374 Arcade Pinball Machine (2026)
DIODIY Long Cat Plush Pillow Cute Body Pillow hot dog pillow cat Toy Soft Sleeping Stuffed Pillow Birthday Gift for Kids